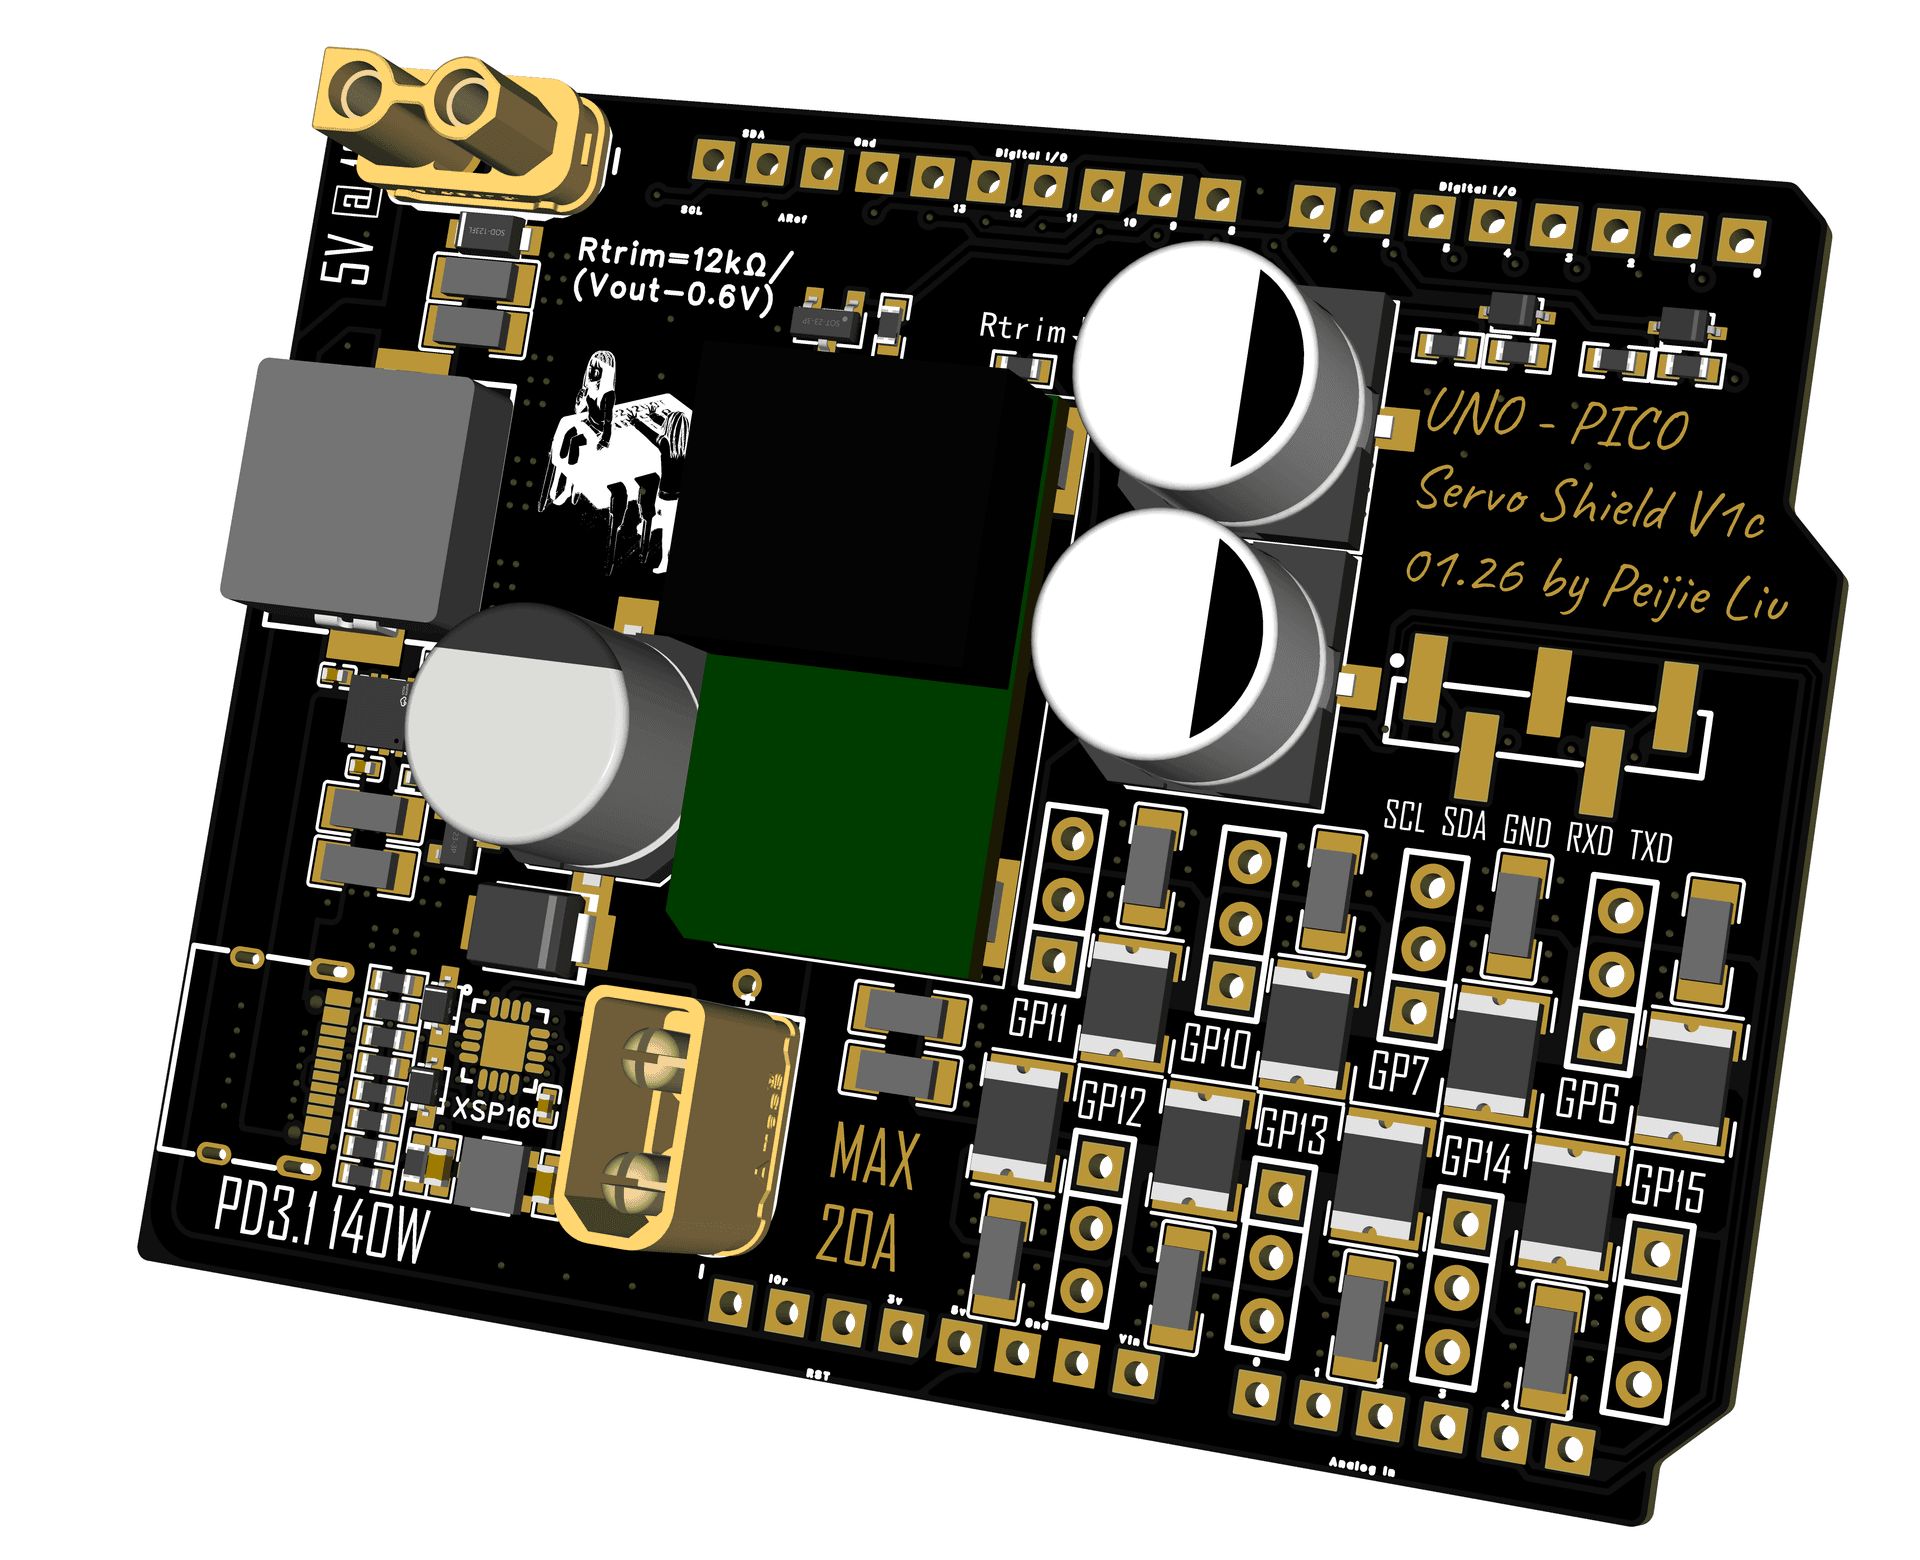
Post-Hackathon Iteration: Designing a Better Servo Driver Shield
After the hackathon chaos, I immediately redesigned a proper servo driver shield - PD3.1 power delivery, Pico coprocessor, and 24A buck converters. Sometimes you just need to build the tool you wish you had.
- Servo rail
- 8.4 V @ 24 A
- PD input max
- 28 V @ 140 W
- Logic rail
- 5 V @ 10 A
- Servo channels
- 8
Building a Mother-Daughter Rover in 36 Hours - Circuit Notes from IEEE Robotech
Quick circuit notes from my first hardcore hackathon - building a quadruped rover with ejectable sub-rover, all hand-wired on protoboard in 36 hours.
- Build time
- 36 hours
- Result
- 1st place
- Servo rail
- 8.4 V 2S LiPo
- Radio failsafe
- 200 ms
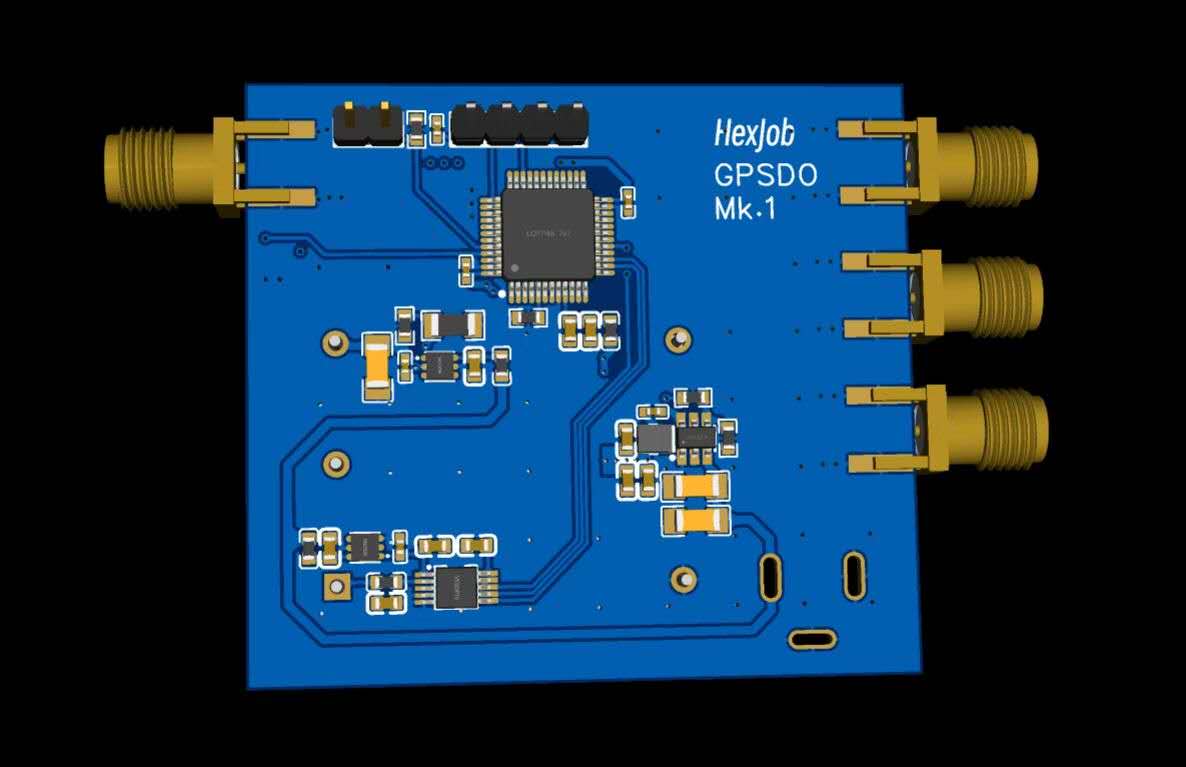
GPS-Disciplined Oscillator (GPSDO) - Achieving 40ppb Accuracy
Testing a custom GPS-disciplined oscillator achieving 40 parts-per-billion frequency accuracy through innovative control algorithms and thermal management.
- Accuracy
- 40 ppb
- Phase noise @1Hz
- < -80 dBc/Hz
- Output power
- +12.06 dBm
- Lock to ±20 ppb
- ~5 min
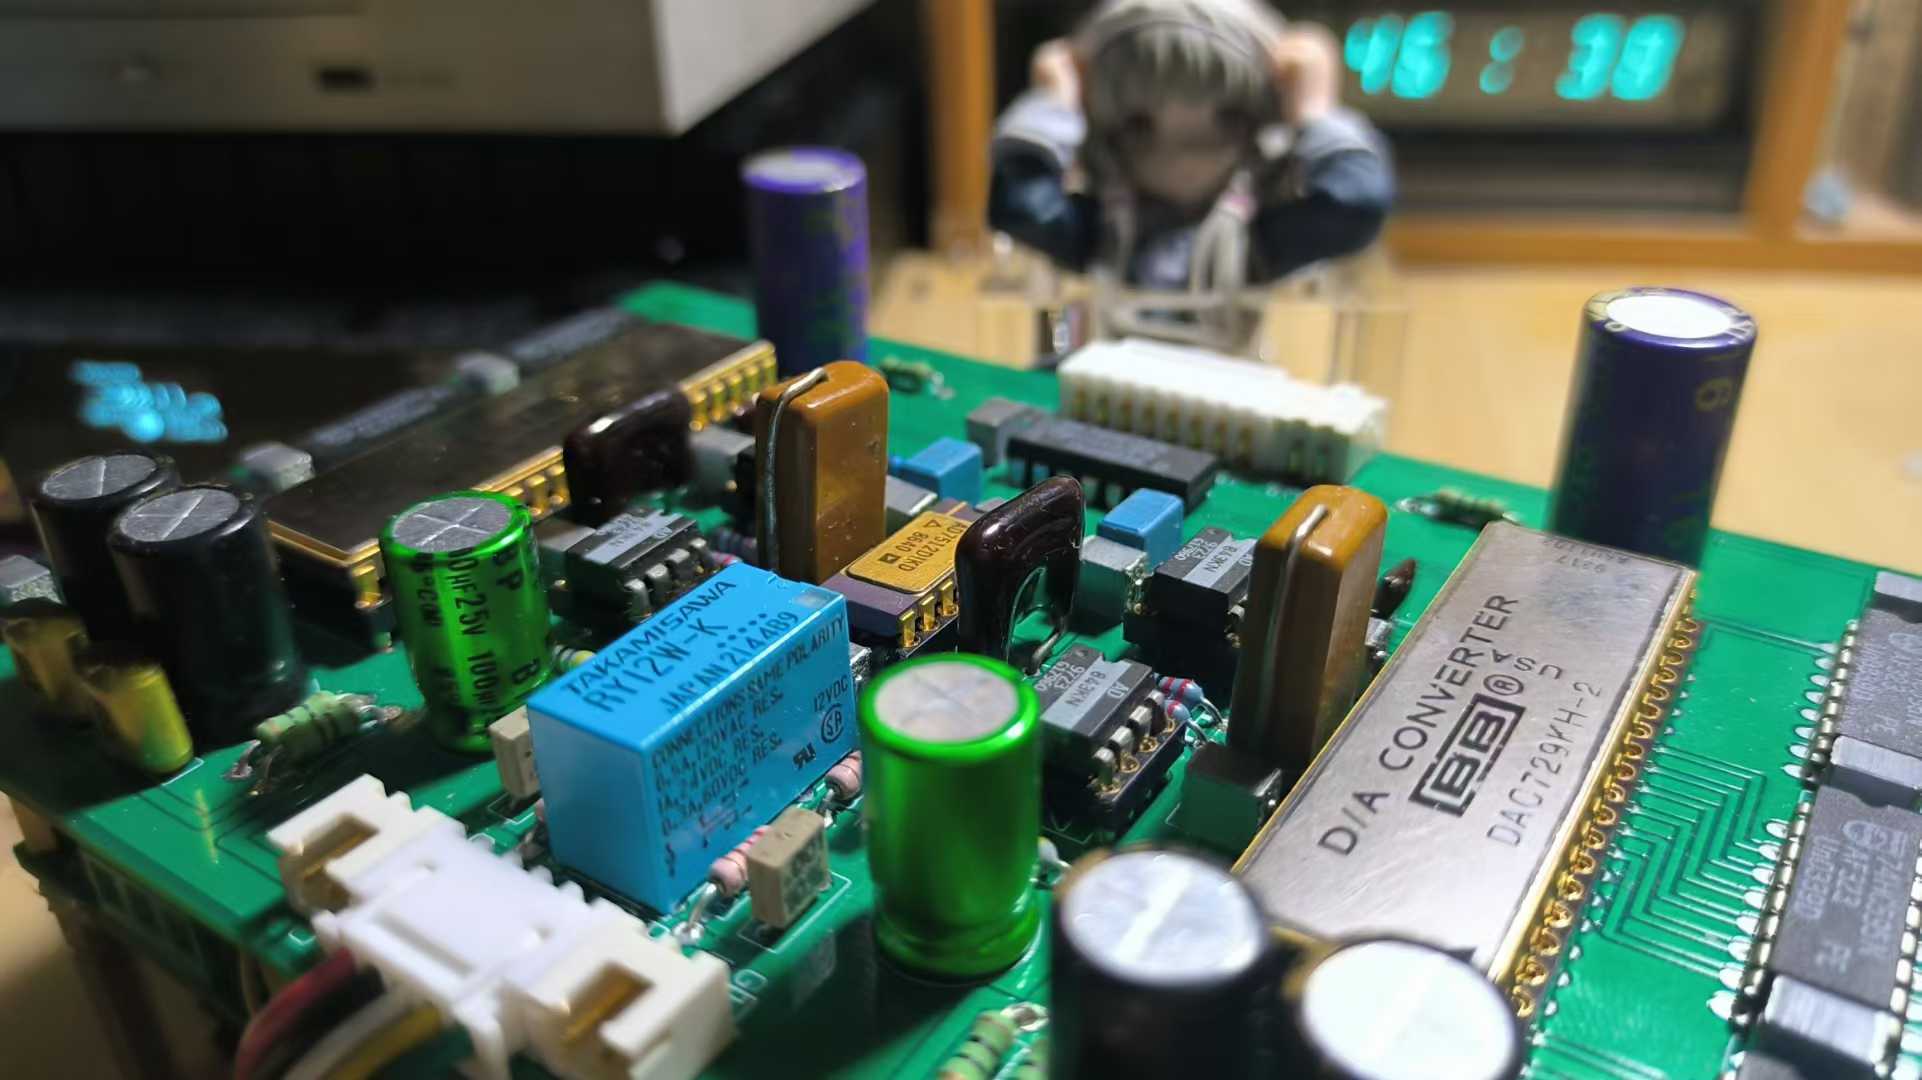
DAC729 - Building a Vintage 18-bit Audio Decoder with 30-Year-Old Silicon
Resurrecting a pair of rare 18-bit DAC729KH chips from the 1990s to build a fully discrete, NOS audio decoder with vintage components and modern innovation.
- THD
- -99.1 dB
- Resolution
- 18-bit R-2R
- Supply
- USB-PD 20 V
Recent Posts